About Me
I am currently a first-year Ph.D. student in ISD at The Hong Kong University of Science and Technology, where I am a member of the Intelligent Graphics Lab (IGL-HKUST), supervised by Prof. Yuan Liu.
Prior to this, I obtained my master's degree from Tsinghua University in 2025, advised by Prof. Haoqian Wang, and my bachelor's degree in Software Engineering from Northwestern Polytechnical University in 2022. I have also been fortunate to work closely with Yikang Ding and Xiaoyu Shi.
My research interests lie in video generation, 3D computer vision, vision-language models (VLMs), and embodied AI, with a focus on enabling intelligent agents to perceive, understand, and interact with the 3D world.
I welcome opportunities to collaborate on related research. Please feel free to email me at yingsh.zou@gmail.com.
Selected Publications
* Equal contribution. † Corresponding author.
 SIGGRAPH Asia 2026
ACM SIGGRAPH Asia Conference Papers, 2026
Fine-grained 3D control for coherent multi-shot video generation through hierarchical narrative conditioning and 3D-aware layout guidance.
 BMVC 2025
British Machine Vision Conference (BMVC), 2025
A controllable multi-modal diffusion framework with Gaussian Splatting for photorealistic urban scene reconstruction and synthesis.
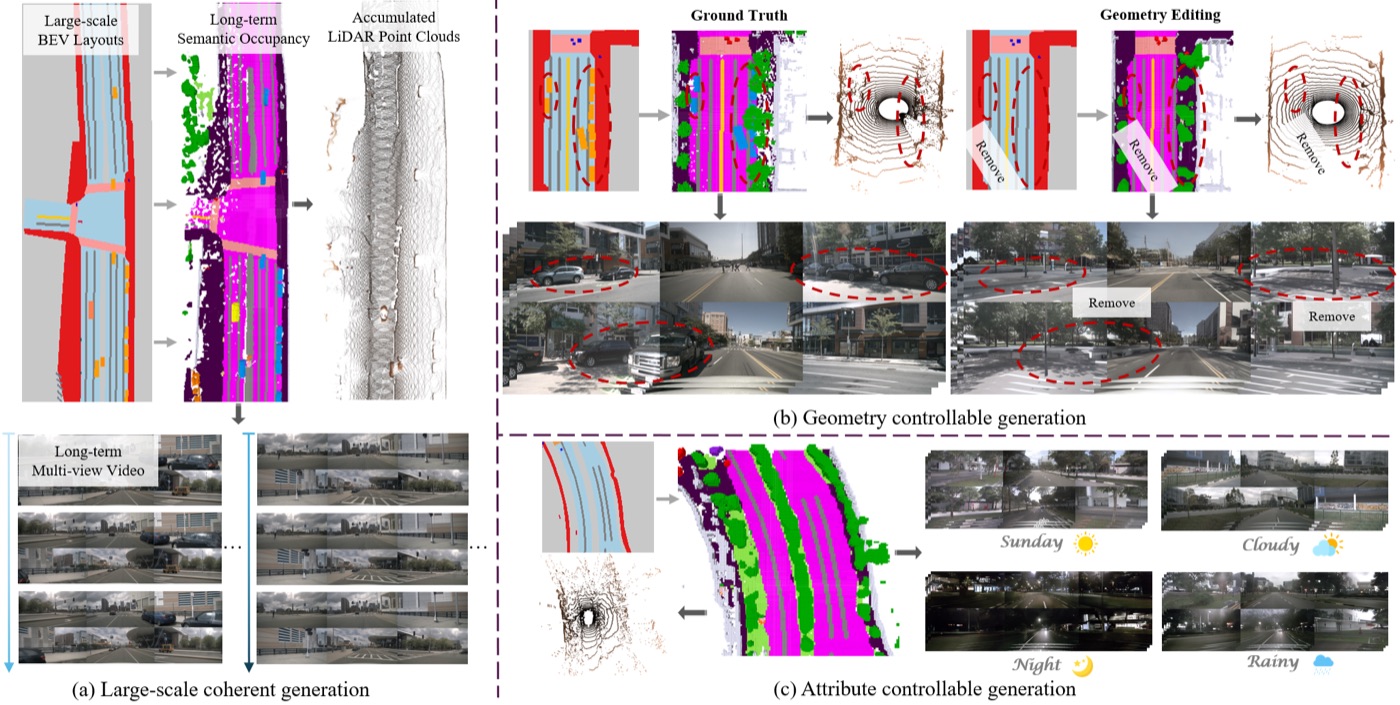 CVPR 2025
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2025
A unified occupancy-centric framework for controllable generation of semantic occupancy, multi-view video, and LiDAR in driving scenes.
 AAAI 2025
AAAI Conference on Artificial Intelligence (AAAI), 2025
A transformer-based approach for generalizable 3D Gaussian Splatting from sparse views with depth-aware feature matching.
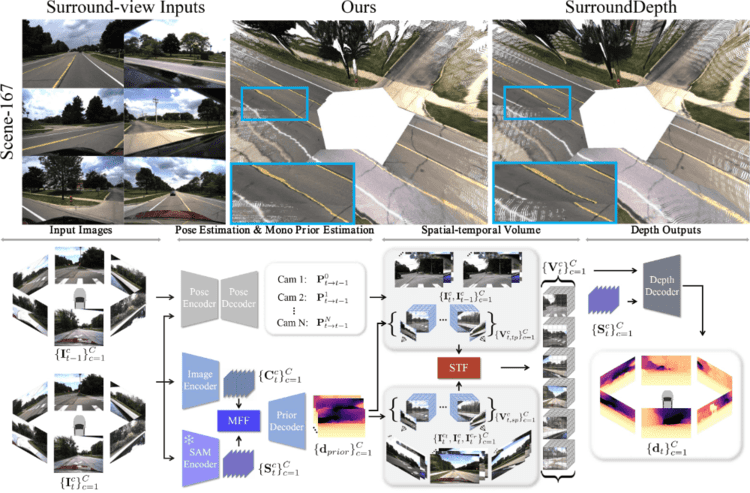 ECCV 2024 Oral
European Conference on Computer Vision (ECCV), 2024 — Oral
Self-supervised metric depth estimation that fuses spatial-temporal information from two-frame surround-view images with strong semantic priors.
Projects
 Research Project
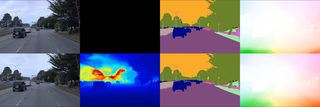
Gaussian Splatting for Dynamic Driving Scenes
Developed a Gaussian Splatting representation for real-time reconstruction and novel-view synthesis of dynamic driving scenes from six surround-view cameras, jointly optimizing appearance, depth, semantics, and optical flow.
Competitions
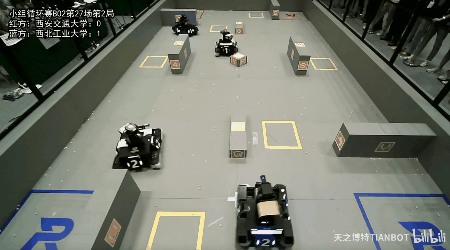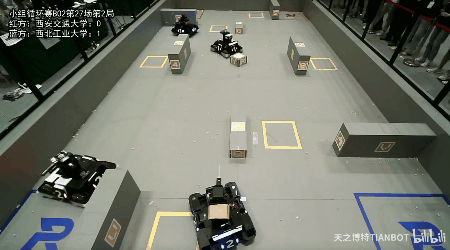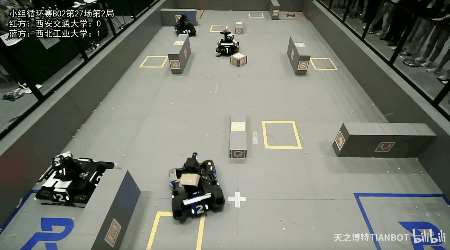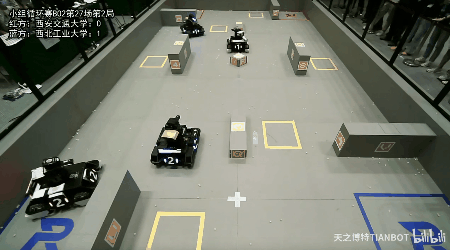 ICRA 2020
DJI RoboMaster AI Challenge
Third Prize · 6th of 72 teams
Developed a Gazebo-based platform for sensor simulation and autonomous navigation, with perception and motion-planning algorithms deployed on physical robots.
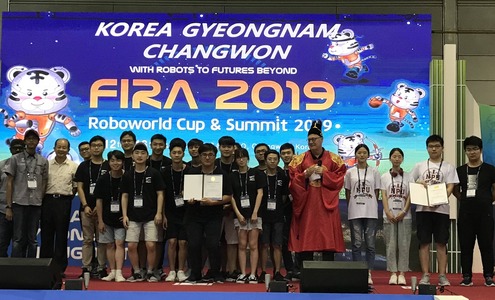 FIRA 2019
FIRA RoboWorld Cup · RoboSot Race
First Prize · 2nd place
Developed navigation and control systems for a LiDAR-equipped wheeled robot, enabling autonomous ball detection and placement in the RoboSot Race.
Experience
Research Intern
